Frederik Heller
Passionate about Robotics and Learning!

printf("%s", "Hello world!"); I am Frederik, a final year Master’s student in Computational Engineering at Technische Universität Darmstadt. This page is still under construction, but feel free to look around or contact me through the links at the bottom!
news
| Oct 13, 2026 | Our paper, Investigating Active Sampling for Hardness Classification with Vision-Based Tactile Sensors, has been accepted for presentation at Humanoids 2026! |
|---|---|
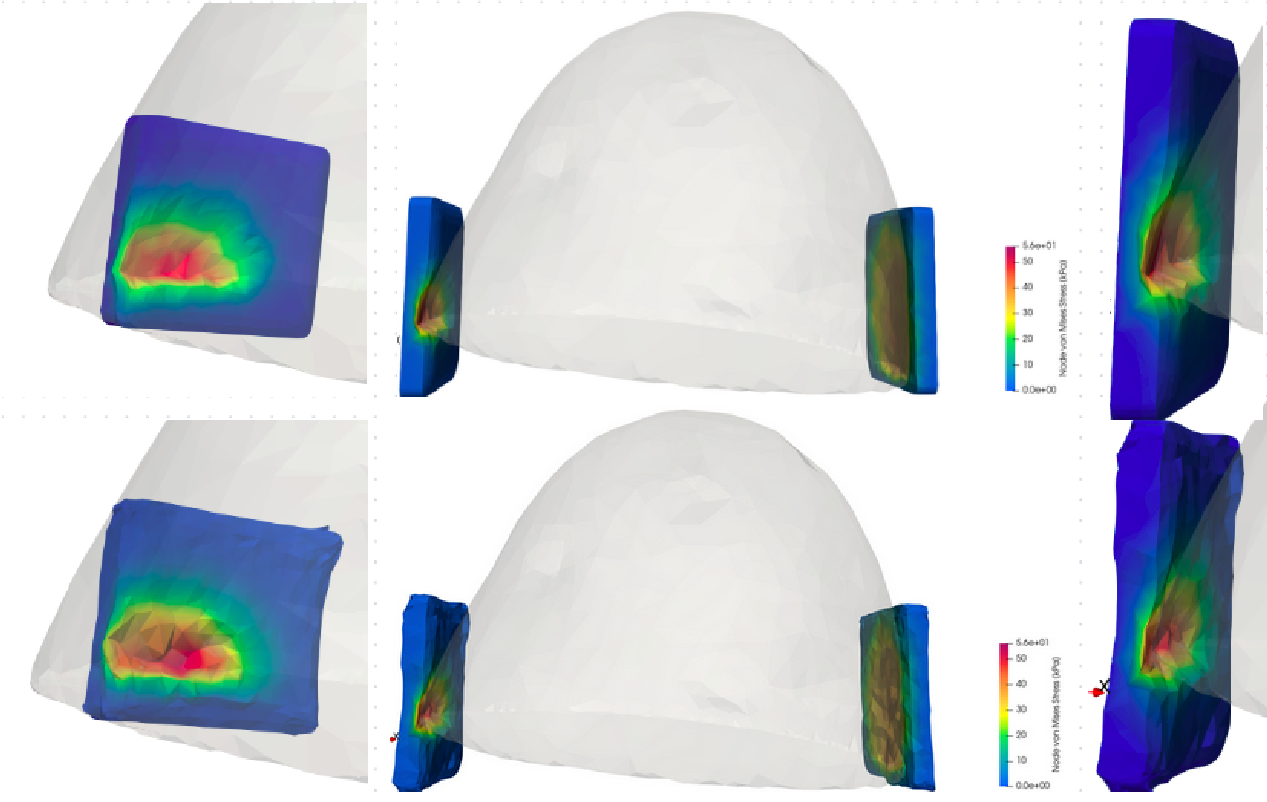
| Apr 07, 2026 | Traveled to Kanazawa, Japan, to present our paper on Real-Time Simulation of Deformable Tactile Sensors and Objects using GNNs with Inductive Biases at RoboSoft 2026. I’m excited that our paper was nominated as a Best Student Paper Award finalist! |
| Oct 24, 2025 | Had a great time in Hangzhou, presenting our two workshop posters at IROS 2025. |
| Sep 06, 2025 | I’ve started my exchange stay with the IIIS at Tsinghua in Beijing, China! |
| Oct 11, 2024 | I have successfully defended my Bachelor’s thesis on Learning Object Stress and Deformation with Graph Neural Networks! |
selected publications
-
 Learning Object Stress and Deformation With Graph Neural NetworksAug 2024Bachelor’s Thesis in the field of study Computational Engineering at Technische Universität Darmstadt. Reviewers: Alap Kshirsagar, Tim Schneider, Guillaume Duret, Jan Peters