publications

publications by categories in reversed chronological order. generated by jekyll-scholar.

2026

  1. duret2025real.png
    Real-Time Simulation of Deformable Tactile Sensors and Objects in Robotic Grasping using Graph Neural Networks with Inductive Biases
    Guillaume Duret, Frederik Heller, Danylo Mazurak, and 5 more authors
    In 2026 IEEE 9th International Conference on Soft Robotics (RoboSoft), Apr 2026
  2. chen2025investigating.png
    Investigating Active Sampling for Hardness Classification with Vision-Based Tactile Sensors
    Junyi Chen, Frederik Heller, Mario Alejandro Gomez Andreu, and 7 more authors
    In 2026 IEEE-RAS 25th International Conference on Humanoid Robots (Humanoids), Apr 2026
    Accepted for presentation; proceedings publication forthcoming
2025

  1. heller2025inductive.png
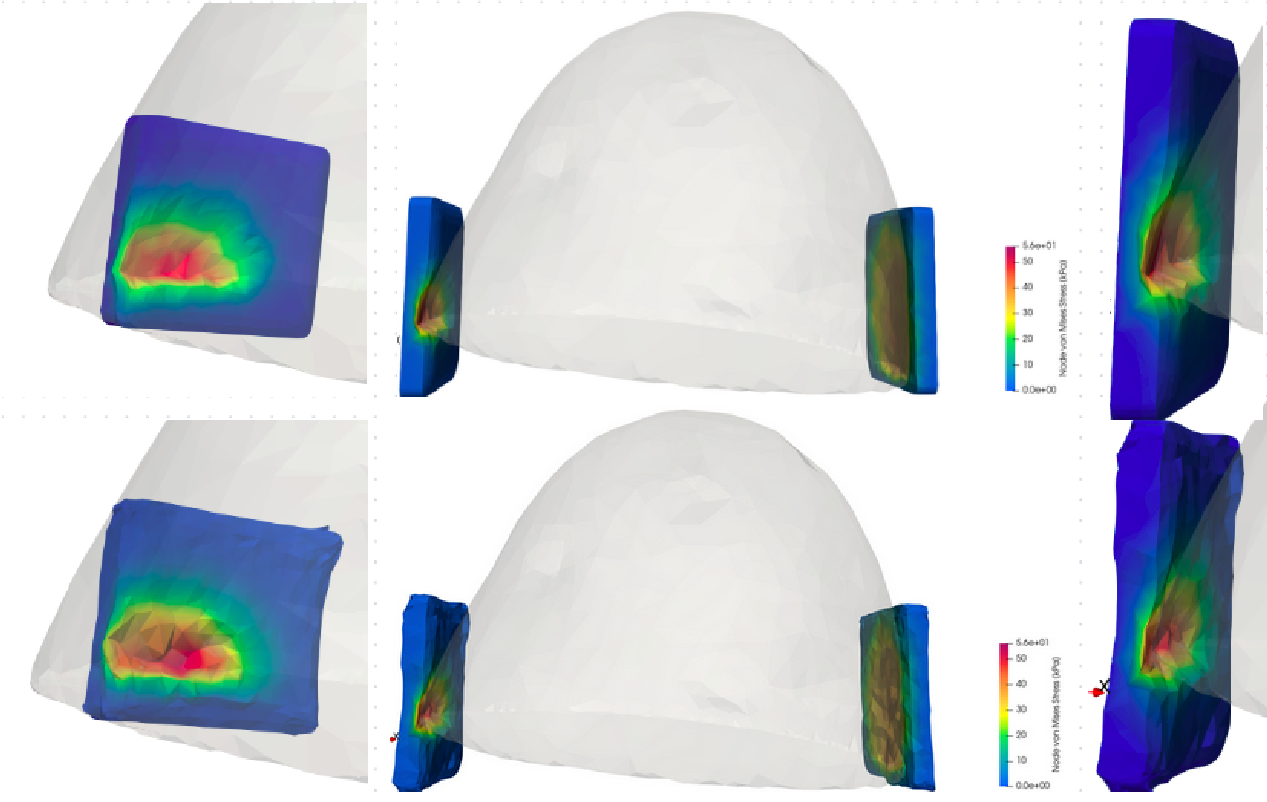
    Inductive Biases for Predicting Deformation and Stress in Deformable Object Grasps with Graph Neural Networks
    Frederik Heller, Alap Kshirsagar, Tim Schneider, and 2 more authors
    In IROS 2025-5th Workshop on RObotic MAnipulation of Deformable Objects: holistic approaches and challenges forward, Oct 2025
  2. duret2025real.png
    Real-Time Simulation of Deformable Tactile Sensors in Robotic Grasping using Graph Neural Networks
    Guillaume Duret, Danylo Mazurak, Frederik Heller, and 4 more authors
    In IROS 2025 Workshop on Tactile Sensing Toward Robot Dexterity and Intelligence, Oct 2025

2024

  1. kshirsagar2024hardness.png
    Hardness Similarity Detection Using Vision-Based Tactile Sensors
    Alap Kshirsagar, Frederik Heller, Mario Gómez Andreu, and 6 more authors
    In 40th Anniversary of the IEEE International Conference on Robotics and Automation (ICRA@40), Sep 2024
  2. heller2024learning.png
    Learning Object Stress and Deformation With Graph Neural Networks
    Frederik Heller
    Aug 2024
    Bachelor’s Thesis in the field of study Computational Engineering at Technische Universität Darmstadt. Reviewers: Alap Kshirsagar, Tim Schneider, Guillaume Duret, Jan Peters